Humanoids
Unitree R1 Platform
Dual-arm robot with high degrees of freedom: ultra-fast deployment, multi-scenario
15-31
Total degrees of freedom
5 of 7 DOF
Degrees of freedom per arm
60 Nm
Max shoulder torque
2-4 kg
Max arm payload
±150° / ±35°
Waist yaw (R1-A / R1-D)
146° × 124°
Binocular camera field of view
10 TOPS
Head module compute
40-100 TOPS
Optional NVIDIA Jetson Orin
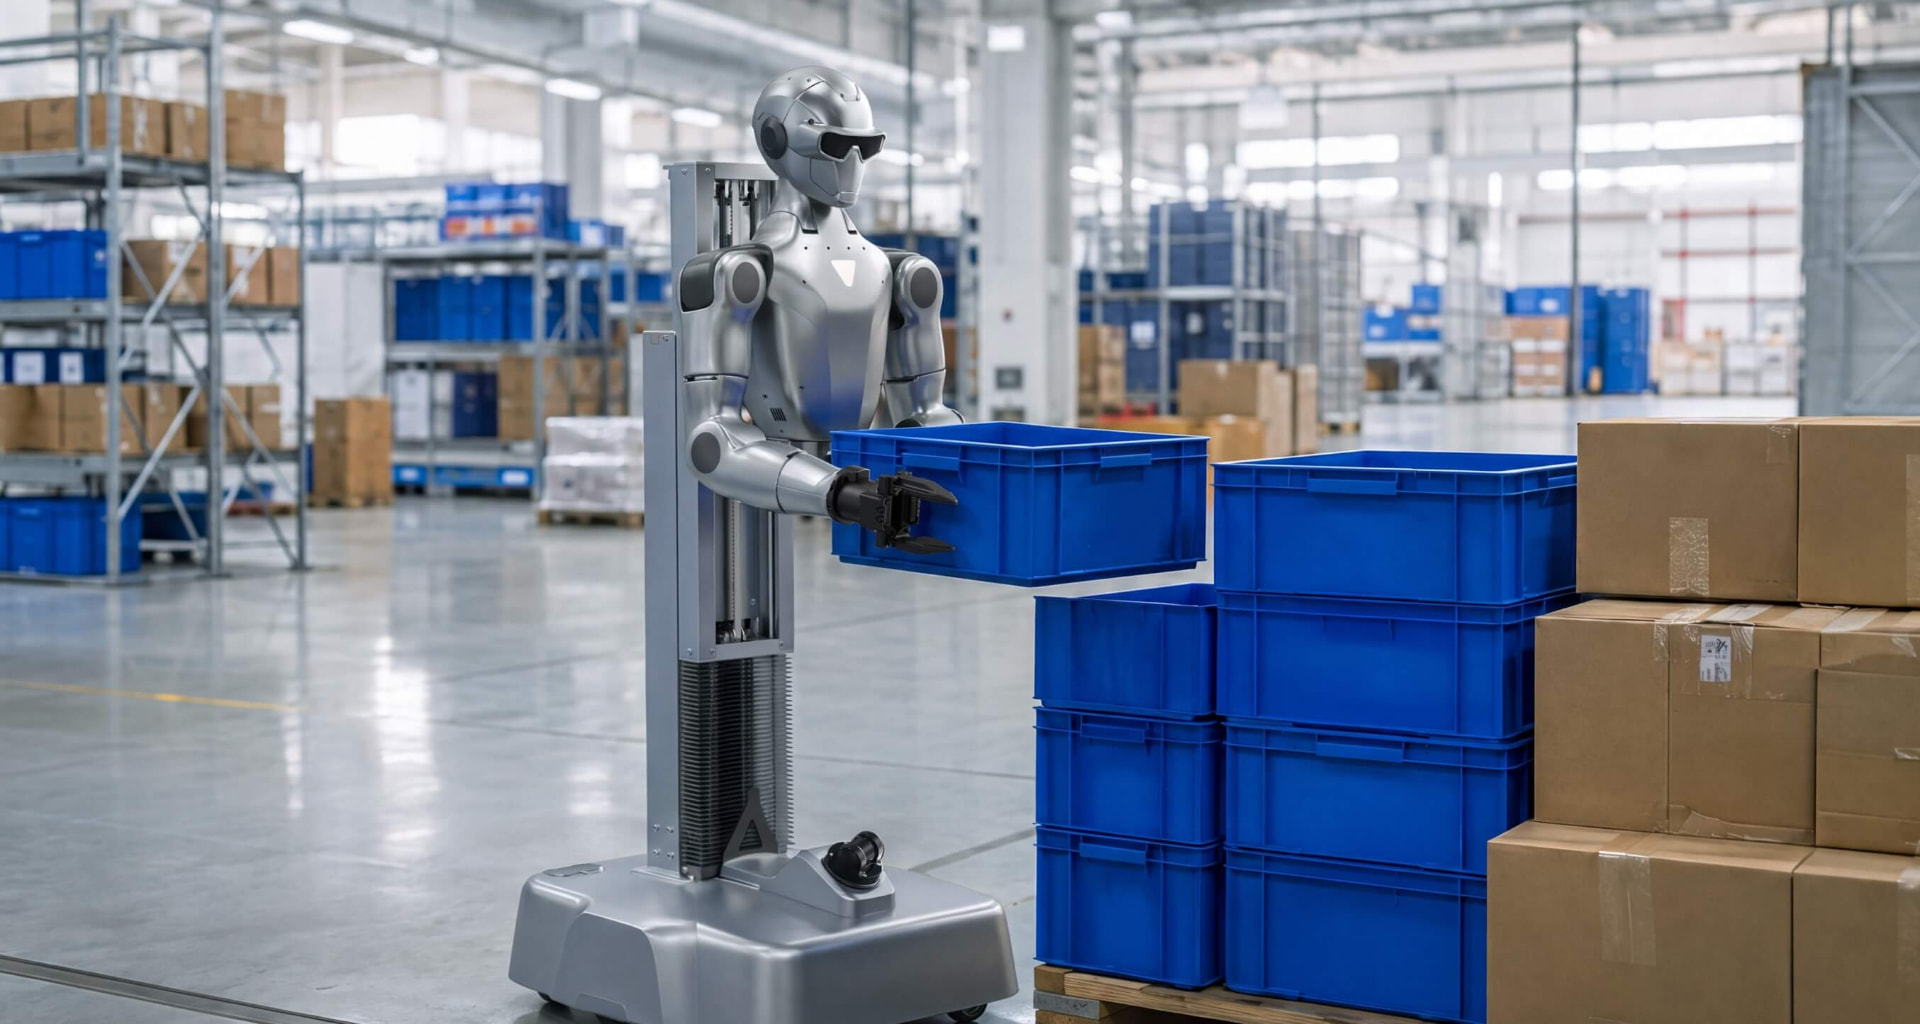
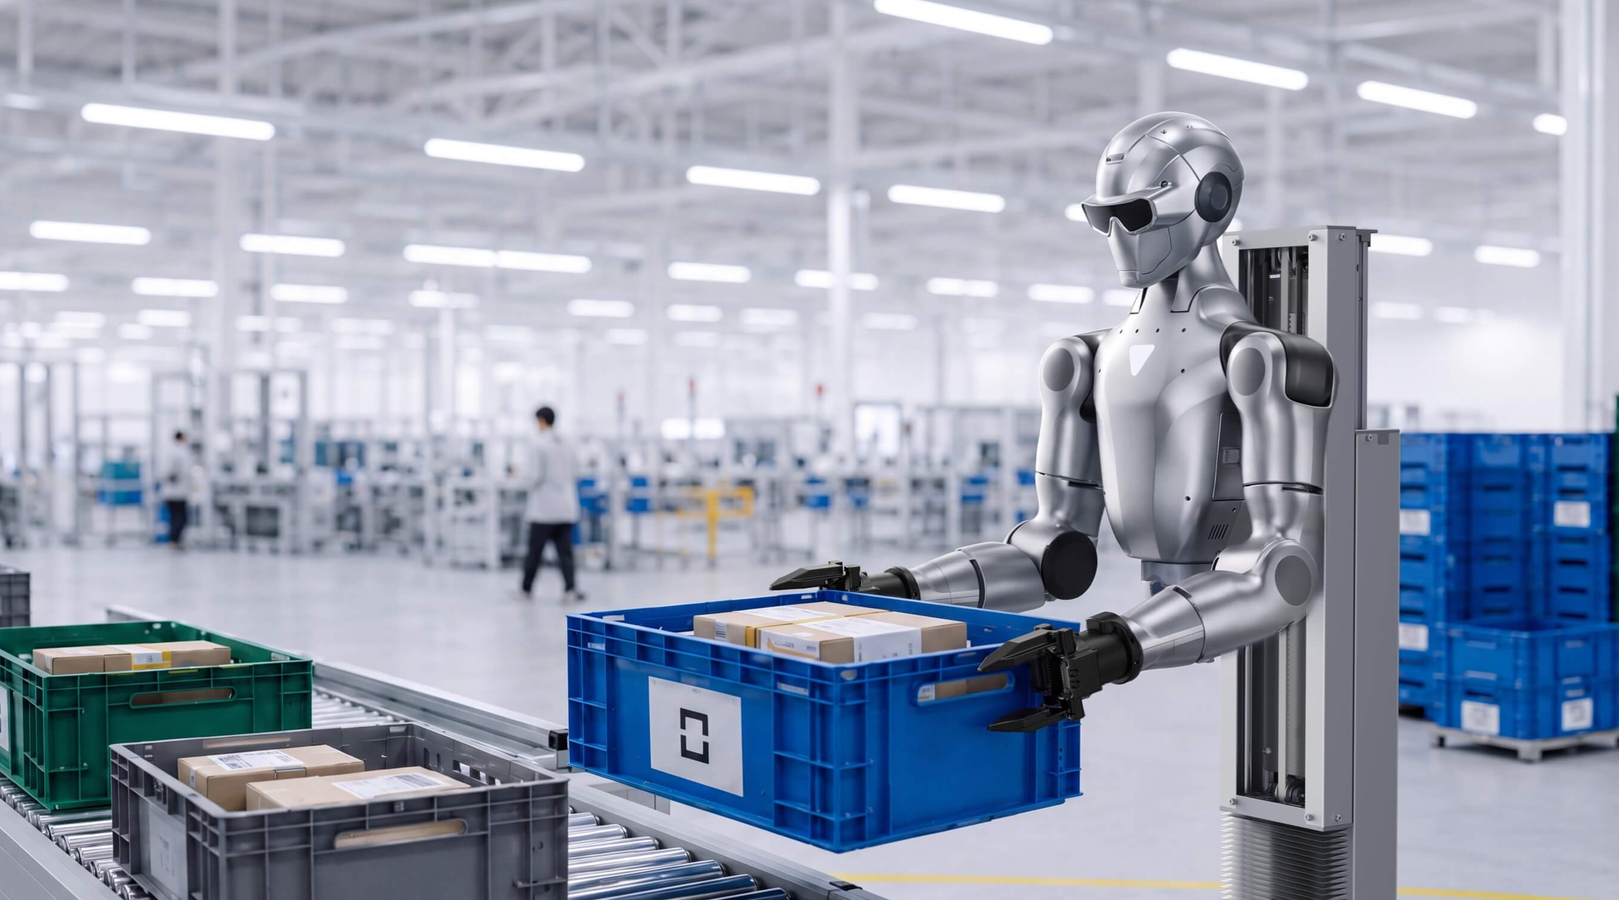
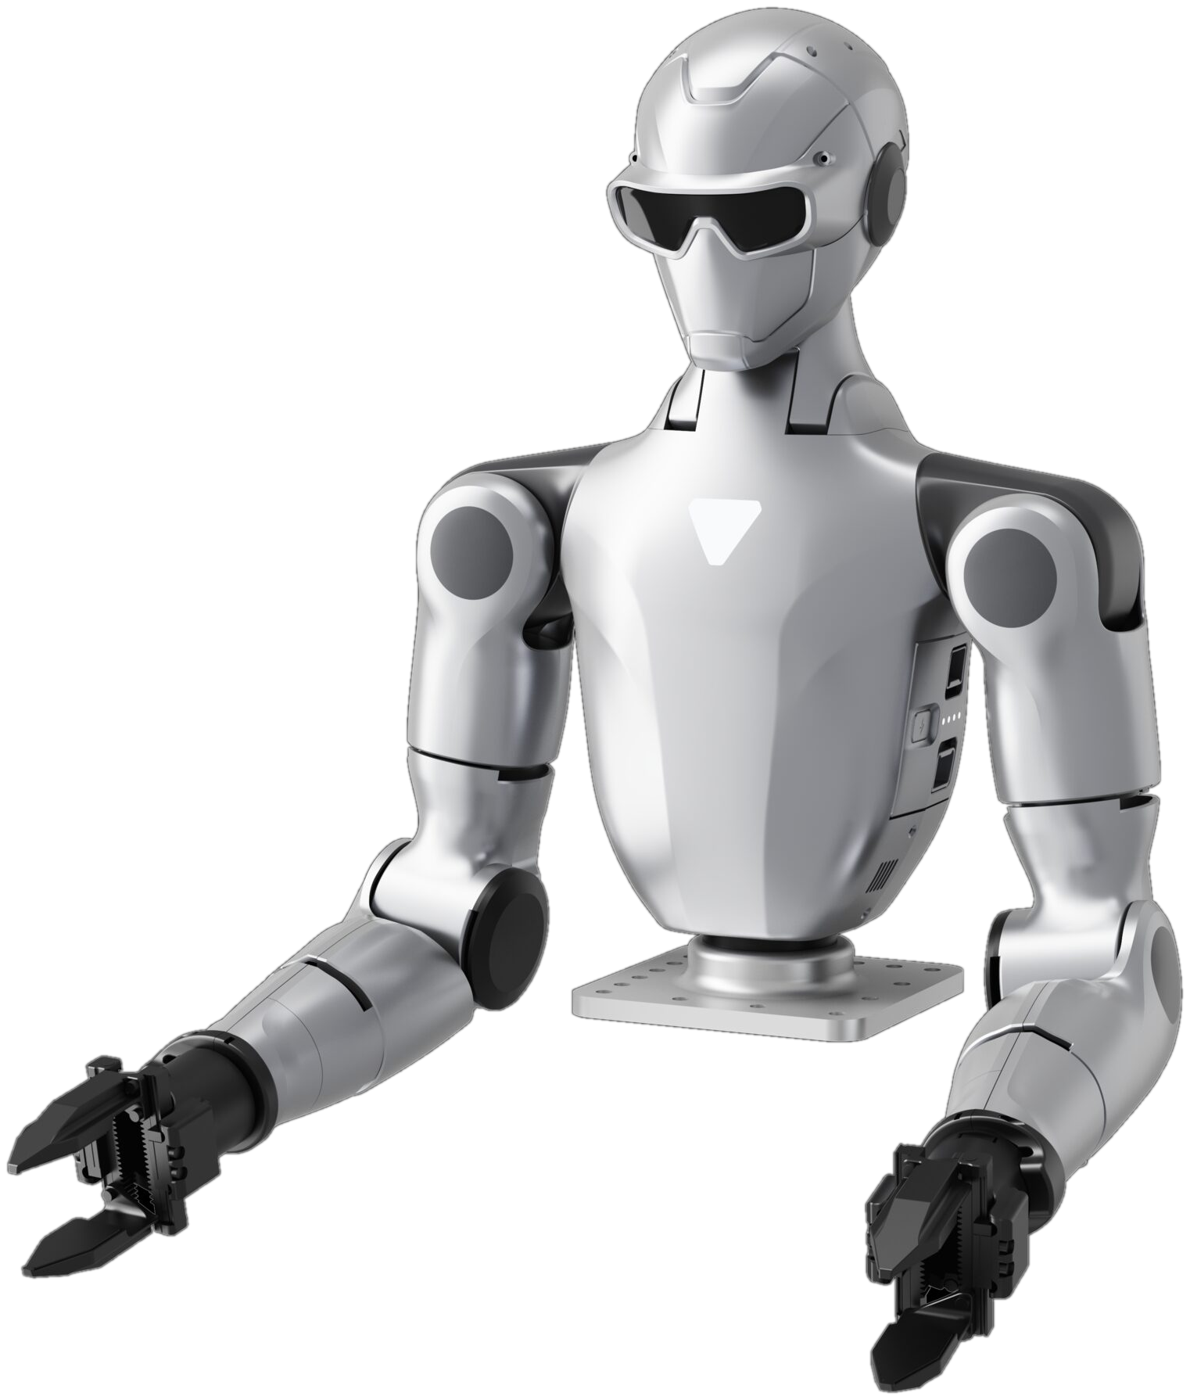
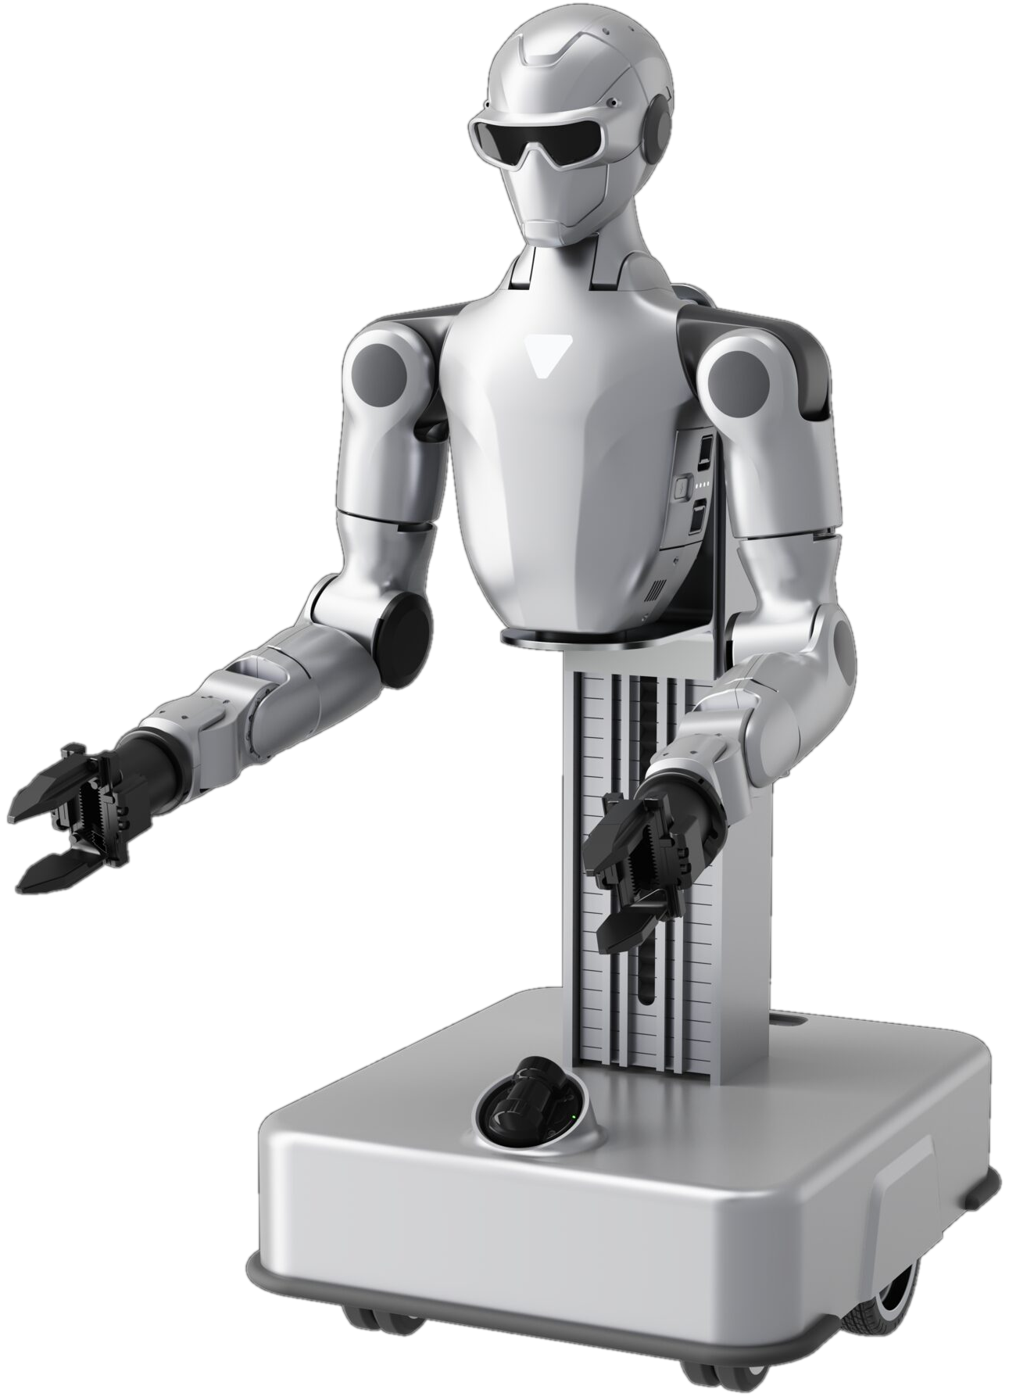
The R1 series is Unitree's dual-arm robot family. The R1-A is the upper body with two arms, waist and head for mounting on a fixed or mobile base; the R1-D adds a motorised, height-adjustable mobile base with chassis LiDAR (683 mm shrunk to 1600 mm raised).
Each version is available with 5 or 7 degrees of freedom per arm (R1-A5 / R1-A7) and with a two-finger gripper, three-finger or five-finger dexterous hand. With 15 to 31 degrees of freedom, 60 Nm shoulder torque, 2 to 4 kg arm payload, stereo vision with RGB and depth, and open interfaces including drag-and-drop teaching, the R1 series deploys quickly for sorting, assembly, machine tending and public interaction.
Highlights
- Modular dual-arm architecture with 15 to 31 degrees of freedom
- Wide working range: waist yaw ±150° (R1-D ±35°), head yaw ±115° and pitch ±36°
- Up to 4 kg arm payload and 60 Nm shoulder torque
- Stereo vision with RGB and depth, 146° × 124° field of view
- Onboard compute with 10 TOPS in the head module, optionally 40-100 TOPS
- Open secondary development and quickly interchangeable tooling
Use cases
- Sorting, order picking and conveyor handling
- Assembly, kitting and two-handed manipulation
- Machine tending and material feeding
- Mobile intralogistics and multi-station workflows
- Visual inspection and process verification
- Robot training, imitation learning and research
Options
- 01R1-A Fixed BaseFixed version for work cells, test setups and production environments. Available as R1-A5 or R1-A7.
- 02R1-D Mobile BaseMobile version with three chassis degrees of freedom and integrated chassis LiDAR. Suitable for multi-station applications.
- 035-DOF or 7-DOF arm configurationChoose between approx. 420 mm arm length at 5-DOF or approx. 555 mm at 7-DOF. The 7-DOF configuration offers extra freedom of movement.
- 04Modular end effectorsConfigurable with a two-finger gripper, three-finger dexterous hand or five-finger dexterous hand, matched to object and process.
- 05Vision and sensor expansionBinocular RGB and depth sensing forms the basis; optional wrist cameras give an extra view of the grasping task. R1-D adds chassis LiDAR.
- 06High-compute moduleExpandable with NVIDIA Jetson Orin configurations of approx. 40 to 100 TOPS for more demanding vision and local artificial intelligence.
- 07Secondary development & Umotion integrationOpen interfaces enable integration with your own software, vision and machine control. Umotion can provide configuration, teaching, integration, training and support.
Key features
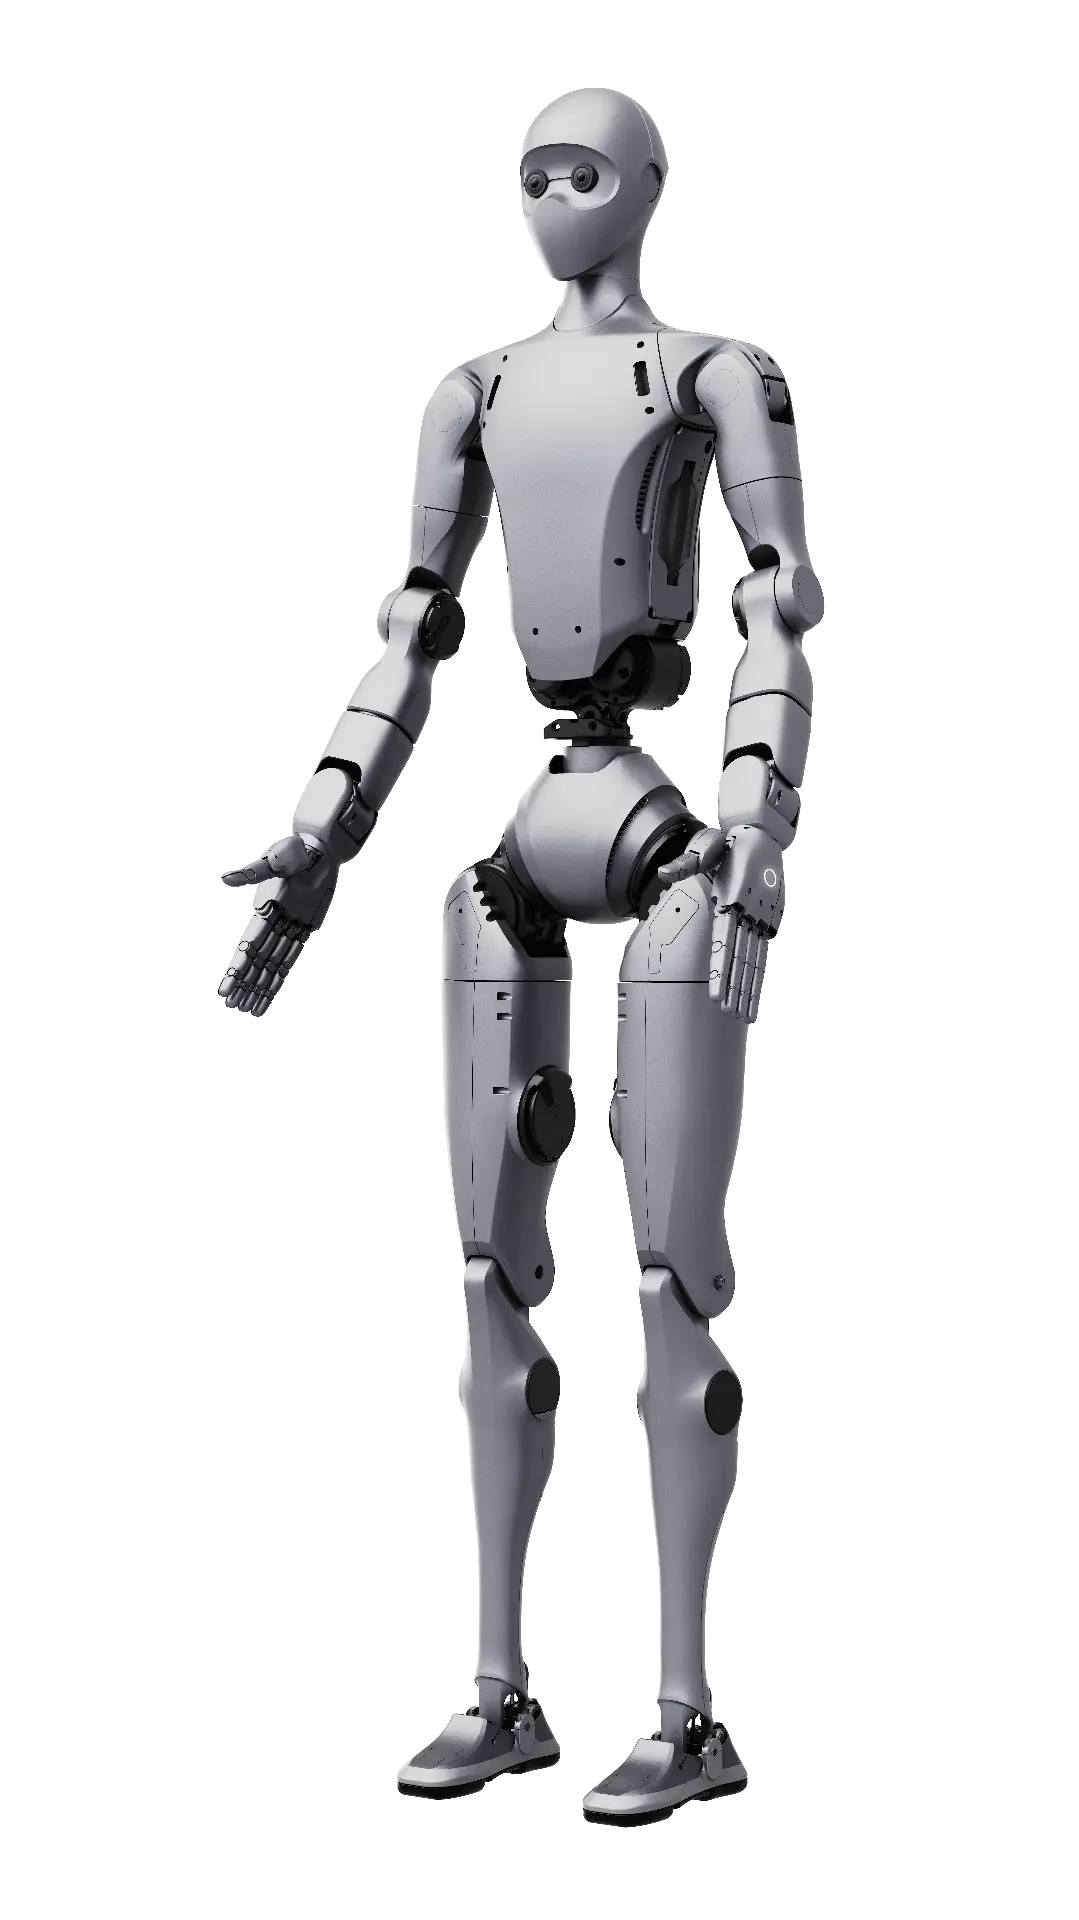
The Unitree R1 platform: R1-A and R1-D dual-arm robots
Modular dual-arm architecture with 15 to 31 degrees of freedom
Depending on configuration: 5 or 7 degrees of freedom per arm, 1 in the waist, 2 in the head and 1 to 7 per end effector. The R1-A5/A7 and R1-A5-D/A7-D offer different levels of reach and manipulation.
Wide working range and high joint dynamics
Fixed R1-A models offer waist yaw up to ±150°; the mobile R1-D models ±35°. The head moves up to ±115° yaw and ±36° pitch, while the 7-DOF arm configuration offers approx. 555 mm arm length.
Up to 4 kg arm payload and 60 Nm shoulder torque
Maximum arm payload is approximately 2 to 4 kilograms, depending on arm posture and configuration. The shoulder joints deliver up to 60 newton metres of torque.
Stereo vision with RGB and depth imaging
Binocular sensing with a 146° horizontal and 124° vertical field of view, RGB up to 1280×720 at 30 Hz and depth up to 544×448 at 10 Hz. The D versions add chassis LiDAR and support optional wrist cameras.
Onboard compute and integrated interaction
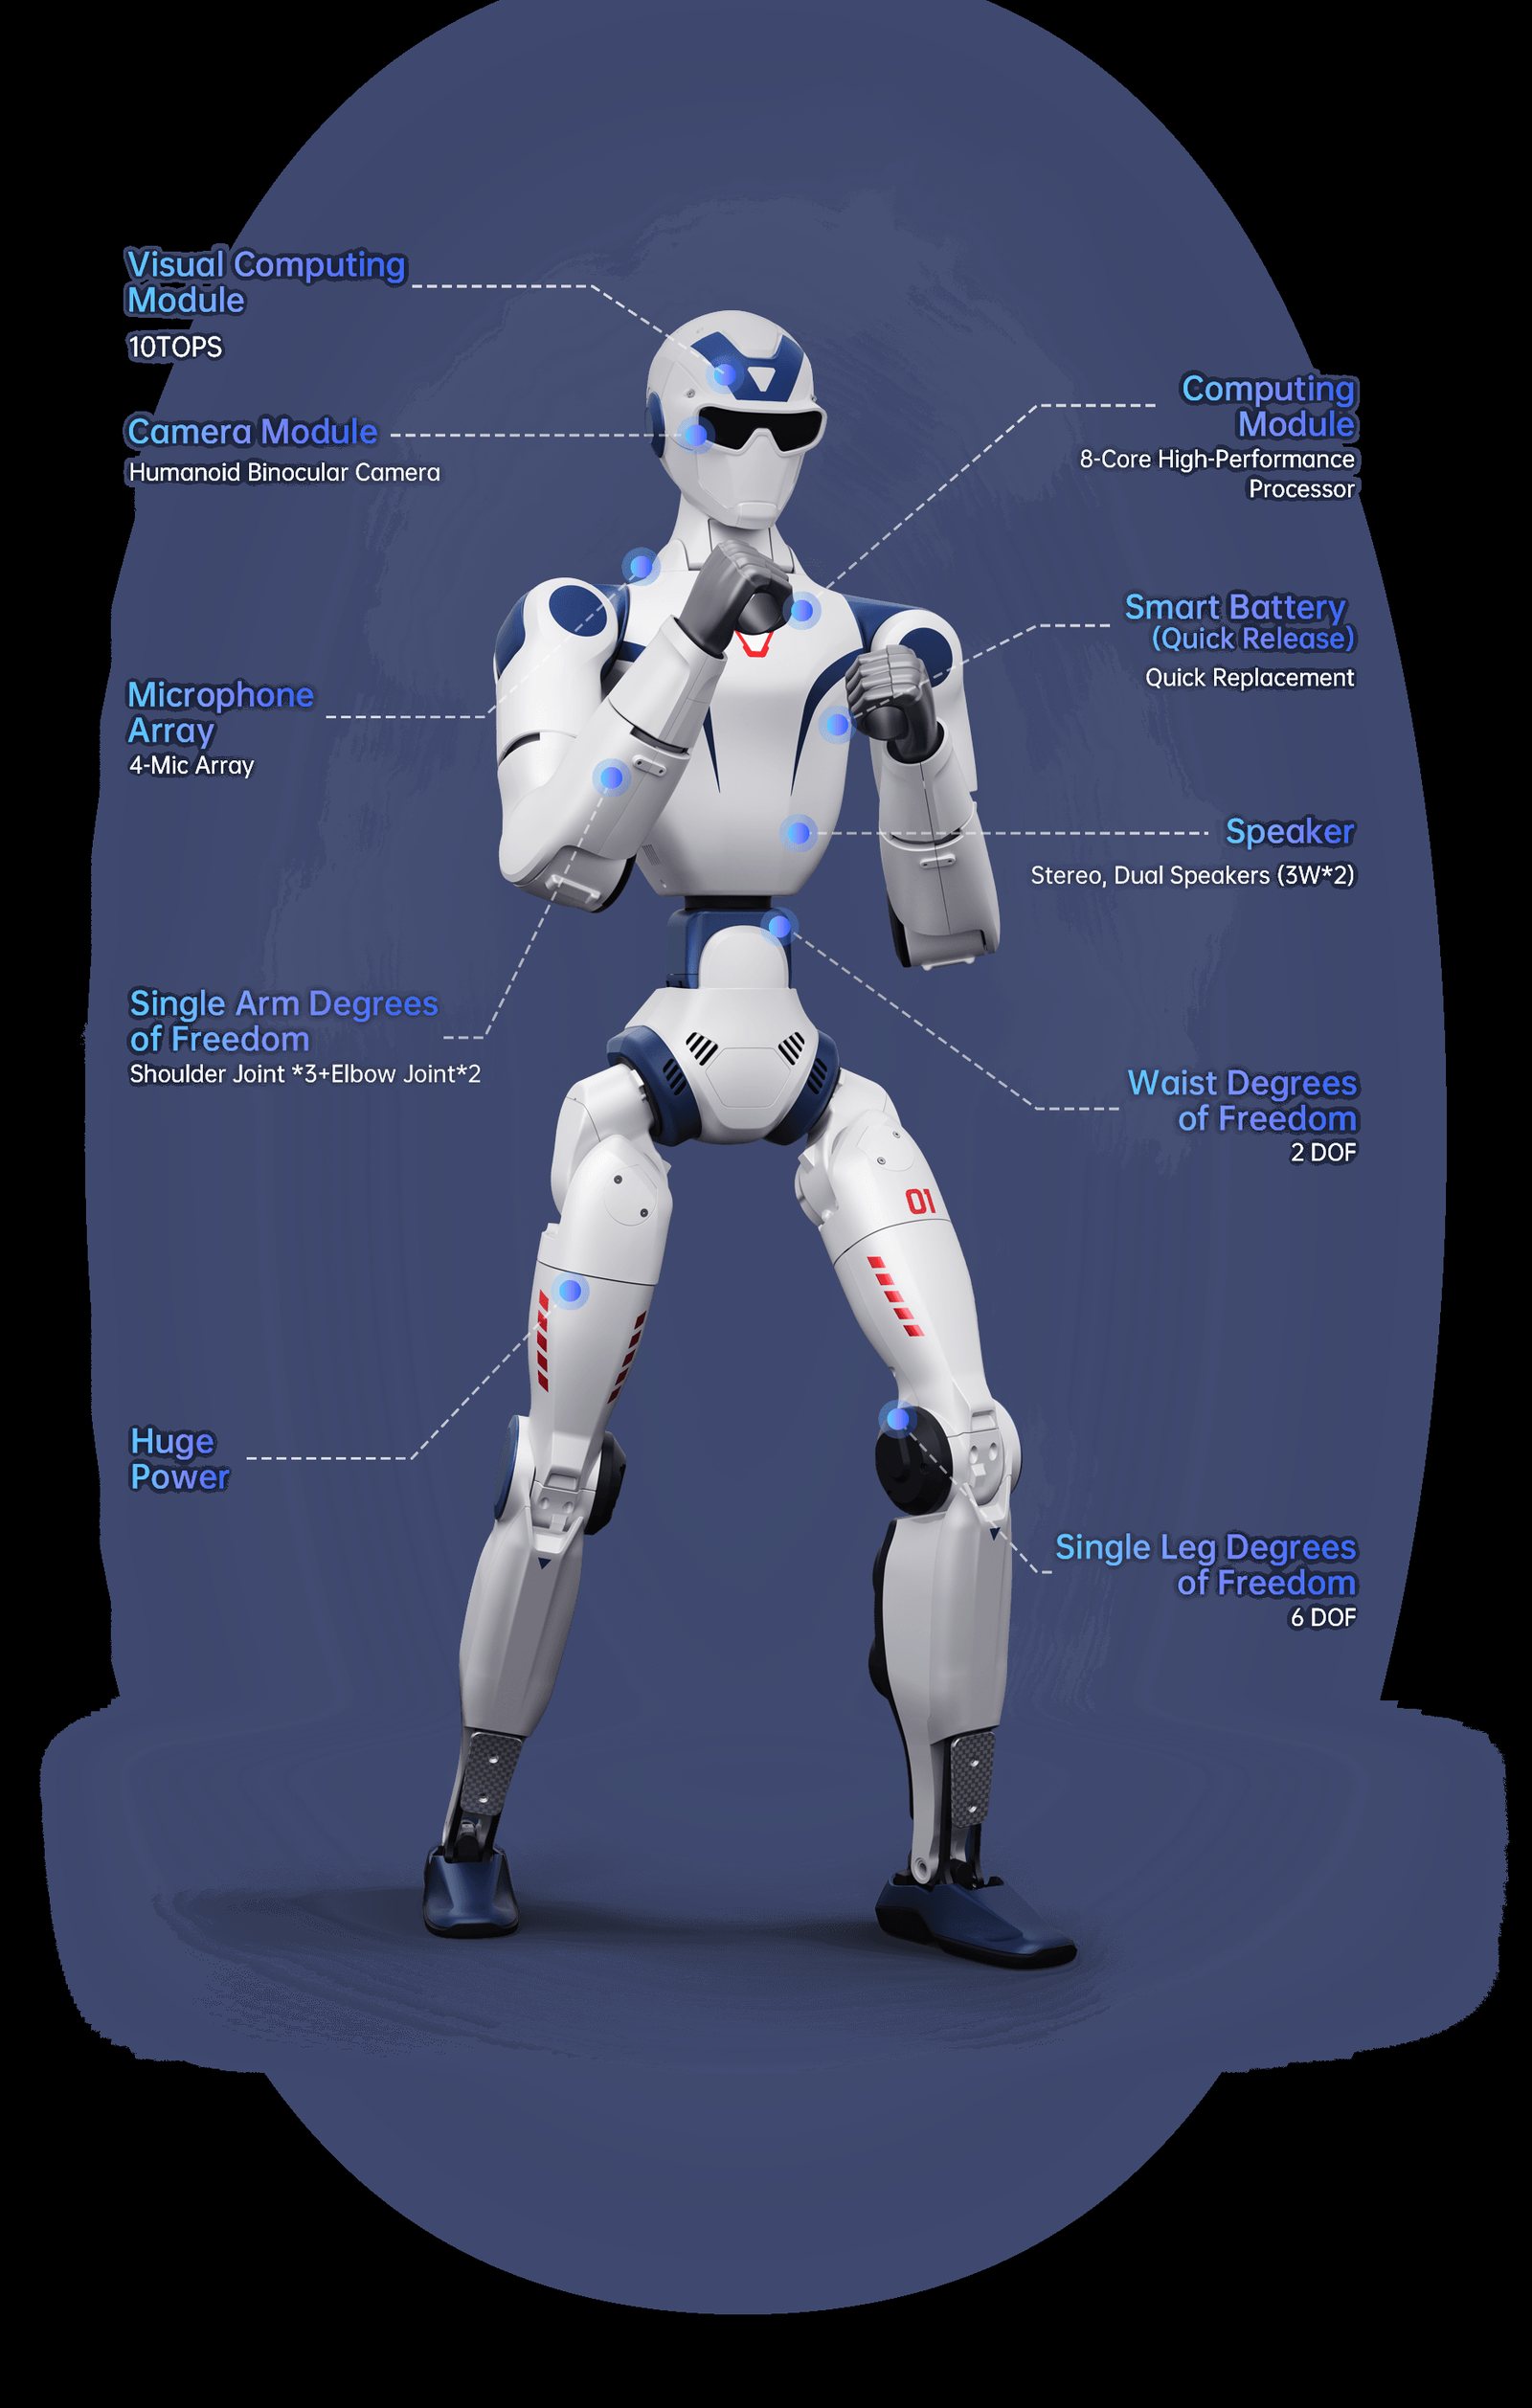
8-core high-performance processors in head and body, with 10 TOPS of compute in the head module. Wi-Fi 6, Bluetooth 5.2, a 4-array microphone and two 3-watt speakers support local control and interaction.
Open secondary development and quickly interchangeable tooling
Open interfaces for system, robotic arms, audio, lighting and vision support customer-specific development and drag-and-drop teaching. End effectors can be swapped quickly for different processes.
Gallery
Versions & options
Unitree R1 Platform
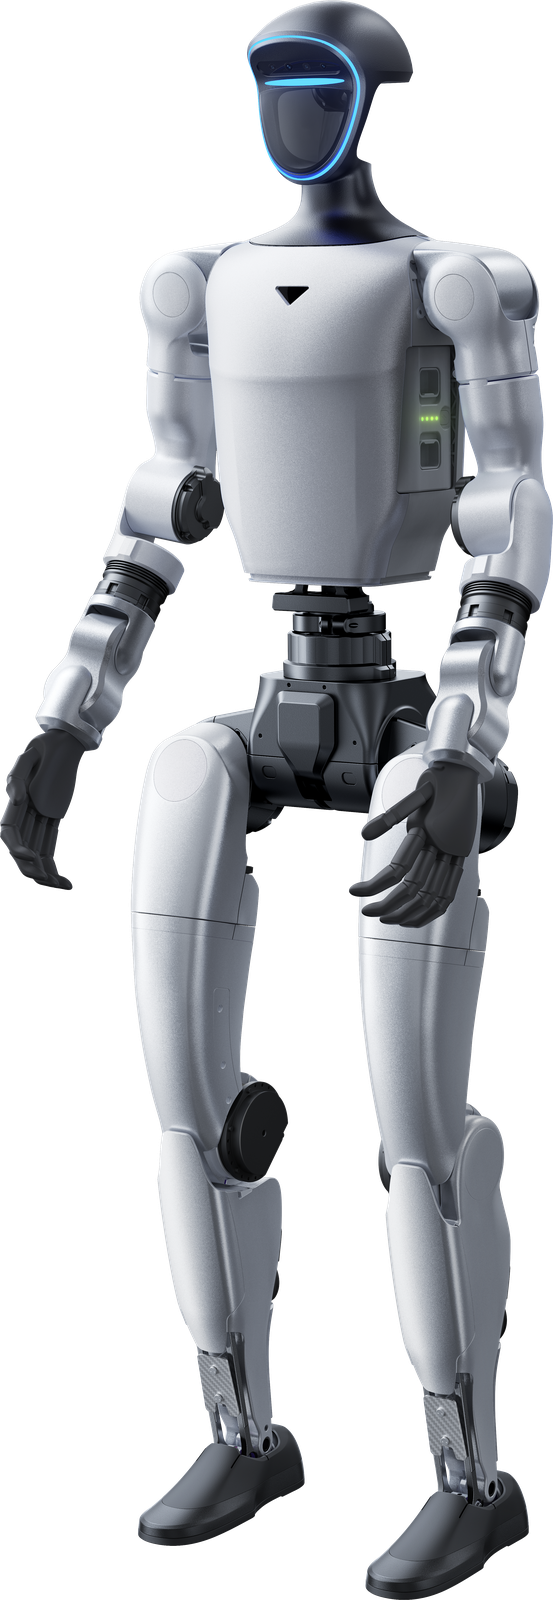
The Unitree R1 is a lightweight humanoid robot of roughly 25 to 29 kg with 26 degrees of freedom, designed as an accessible development platform for research, education and business applications. Its low weight, fluid gait and arm motion, and multimodal AI with speech and vision make it immediately usable for human interaction, demonstrations and motion research. With full SDK access, expansion docks up to 100 TOPS and a free choice of multifunctional robot hands, LiDAR and camera modules, the R1 can be extended exactly to your own algorithms, sensors and processes. The R1-A and R1-D versions place the same platform on a fixed or mobile base for workstation and front-desk deployments.
Versions
- R1 BasicApprox. 29 kg and 26 DOF (leg 6, waist 2, arm 5, head 2), including a 2-DOF head.
- R1 EDU StandardBasic configuration with full SDK access for secondary development.
- R1 EDU SmartEDU Standard with a 100 TOPS expansion module for custom AI algorithms.
- R1 EDU Professional A – HEDU Smart with the hand configuration of your choice: A/B Dex3-1 without or with tactile sensing (40 DOF total), C/D BrainCo Revo 2, E/F Linker Hand O6, G Dex1-1, H Dex2/5. All versions with wrist RGB camera.
- R1-AR1 on a mobile or fixed base for workstations and front-desk applications.
- R1-DDual-arm humanoid on a fixed or mobile base. Fast to set up, with dual-camera vision module and voice interaction; hands selected from the R1 range.
Options & accessories
- Lichtgewicht platformApprox. 25–29 kg, easy to transport and set up by one person.
- 26 vrijheidsgradenFluid walking, balancing and arm motion with natural dynamics.
- Multimodale AISpeech and vision recognition for direct human interaction.
- Open ontwikkelplatformFull SDK access for custom algorithms and secondary development.
- Rekenkracht tot 100 TOPSExpansion dock for running your own AI models on board.
- Vrije sensor- en handkeuzeCombine multifunctional robot hands, LiDAR and camera modules as needed.
Full specifications
Unitree R1 Platform
Mechanical Dimensions
| Specificatie | R1 | R1 EDU | R1-A7 | R1-A7-D |
|---|---|---|---|---|
| Dimensions | 1230x357x190 mm (standing) | 1230x357x190 mm (standing) | 835x357x190 mm | Retracted: 683x520x440 mm / Extended: 1600x520x440 mm |
| Weight | approx. 29 kg (with battery) | approx. 29 kg (with battery) | approx. 13 kg (with external power supply) | approx. 32 kg |
| Degrees of freedom (total) | 26 | 26-40 | 19 | 22 |
| DOF per leg | 6 | 6 | — | — |
| DOF per arm | 5 | 5 | 7 | 7 |
| Waist DOF | 2 | 2 | 1 | 1 |
| Head DOF | 2 | 2 | 2 | 2 |
| Chassis DOF | — | — | — | 3 |
| End effector [2] | — | Optional dexterous hand | Optional two-finger gripper / three- or five-finger dexterous hand | Optional two-finger gripper / three- or five-finger dexterous hand |
| Joint output bearing | Crossed-roller bearing + double angular contact ball bearing | Crossed-roller bearing + double angular contact ball bearing | Crossed-roller bearing + deep groove ball bearing | Crossed-roller bearing + deep groove ball bearing |
| Joint motor | Low-inertia high-speed inner-rotor PMSM | Low-inertia high-speed inner-rotor PMSM | Low-inertia high-speed inner-rotor PMSM | Low-inertia high-speed inner-rotor PMSM |
| Max shoulder torque | — | — | 60 Nm | 60 Nm |
| Max arm payload [1] | approx. 2 kg | approx. 2 kg | 2~4 kg | 2~4 kg |
| Calf + thigh length | 600 mm | 600 mm | — | — |
| Forearm + upper arm length | 420 mm | 420 mm | 555 mm | 555 mm |
| Joint motion range | Waist: yaw ±150°, roll ±30° / Knee: -10°~+139° / Hip: yaw ±157°, pitch -168°~+146°, roll -60°~+100° | Waist: yaw ±150°, roll ±30° / Knee: -10°~+139° / Hip: yaw ±157°, pitch -168°~+146°, roll -60°~+100° | Waist: yaw ±150° / Head: yaw ±115°, pitch ±36° | Waist: yaw ±35° / Head: yaw ±115°, pitch ±36° |
| End-clamp accuracy | — | — | ±0,1 mm | ±0,1 mm |
Electrical Characteristics
| Specificatie | R1 | R1 EDU | R1-A7 | R1-A7-D |
|---|---|---|---|---|
| Wiring | Hollow + internal cabling | Hollow + internal cabling | Hollow + internal cabling | Hollow + internal cabling |
| Joint encoder | Double + single encoder | Double + single encoder | Double encoder (arm) | Double encoder (arm) |
| Cooling system | Local air cooling | Local air cooling | Local air cooling | Local air cooling |
| Power supply | Lithium-ion battery | Lithium-ion battery | External power supply or li-ion battery | External power supply or li-ion battery |
| Base computing power | 8-core high-performance processor | 8-core high-performance processor | Body: 8-core CPU / Head: 8-core CPU + 10 TOPS | Body: 8-core CPU / Head: 8-core CPU + 10 TOPS |
| Microphone | 4-array | 4-array | 4-array | 4-array |
| Speaker | Yes | Yes | Dual speaker (3W×2) | Dual speaker (3W×2) |
| WiFi 6 & Bluetooth 5.2 | Yes | Yes | Yes | Yes |
| Camera module | Stereo camera | Stereo camera | Stereo camera (FOV 146°×124°) + optional wrist camera | Chassis LiDAR + stereo camera + optional wrist camera |
Accessories
| Specificatie | R1 | R1 EDU | R1-A7 | R1-A7-D |
|---|---|---|---|---|
| High-power computing module | — | Optional NVIDIA Jetson Orin (40-100 TOPS) | Optional NVIDIA Jetson Orin (40-100 TOPS) | Optional NVIDIA Jetson Orin (40-100 TOPS) |
| Smart battery (quick release) | Yes | Yes | — | — |
| Power input | — | — | Yes | Yes |
| Charger | Included | Included | Included | Included |
| Manual controller | Yes | Yes | Optional | Optional |
Other
| Specificatie | R1 | R1 EDU | R1-A7 | R1-A7-D |
|---|---|---|---|---|
| Battery life | Approx. 1 hour | Approx. 1 hour | Approx. 1.5 hours | Approx. 1.5 hours |
| Smart OTA update | Yes | Yes | Yes | Yes |
| Secondary development [3] | — | Yes | Yes | Yes |
| Warranty period [4] | 8 months | 12 months | 12 months | 12 months |
Read more
Humanoid robots in factories: applications with G1, R1 and H2 Plus
G1, R1 and H2 Plus for handling, internal logistics and development: compare platforms around the factory task and required configuration.
4 min read
How much does a humanoid robot cost? Prices and what determines them
Unitree R1, G1 and H2 Plus starting prices, excluding VAT. See how configuration, accessories and options determine the final price.
3 min read
Frequently asked questions
From € 10.595 excl. VAT* * All listed prices are starting prices, excluding VAT, and depend on configuration, accessories and optional additions. These are entry-level prices for consumer use or marketing purposes, not for industrial applications. Industrial configurations are quoted on request.
Sorting, order picking and conveyor handling; Assembly, kitting and two-handed manipulation; Machine tending and material feeding.
R1 Basic; R1 EDU Standard; R1 EDU Smart; R1 EDU Professional A – H; R1-A; R1-D.
Yes. Umotion supplies Unitree robots and accessories in the Netherlands, Belgium and Luxembourg: the Benelux.
Umotion offers advice, integration, training and service. Discuss which support suits your application and configuration when making your enquiry.
R1 EDU Standard: Basic configuration with full SDK access for secondary development.
Robot training, imitation learning and research.
Also of interest
* All listed prices are starting prices, excluding VAT, and depend on configuration, accessories and optional additions. These are entry-level prices for consumer use or marketing purposes, not for industrial applications. Industrial configurations are quoted on request.